Overview
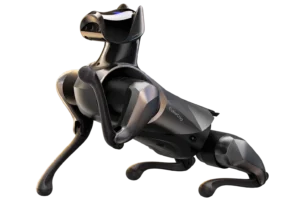
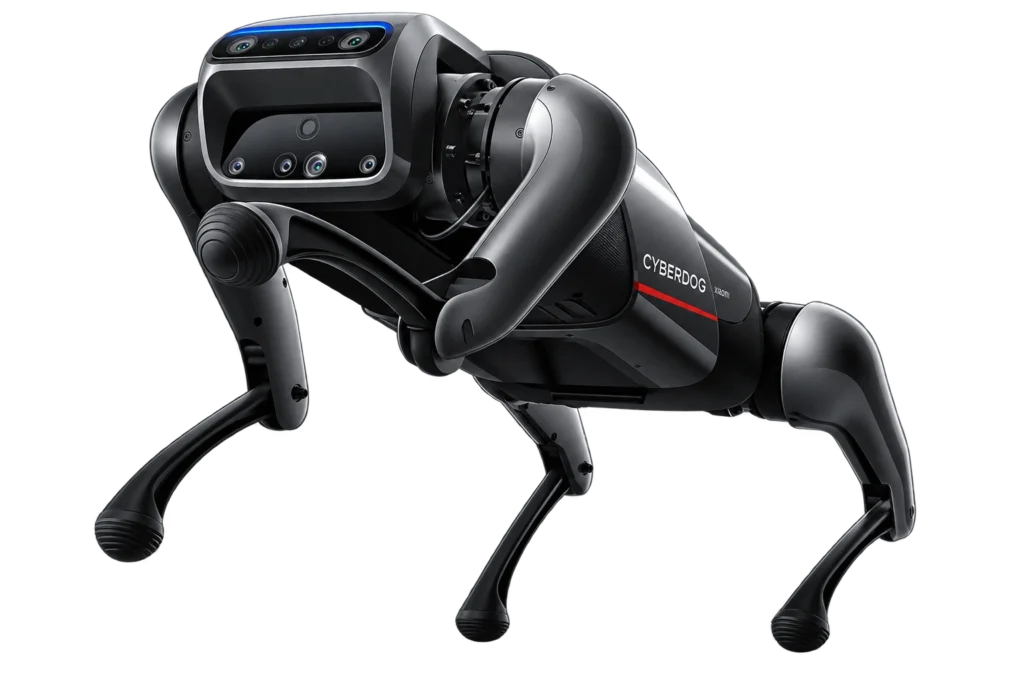
This profile keeps the original CyberDog separate from CyberDog 2. Its official repository documents perception, interaction, navigation and software development. Earlier launch pricing is retained only as a clearly labeled historical reference; current hardware availability and firmware support require confirmation.
Capabilities & applications
- ROS 2 development
- Navigation software
- Multimodal interaction
Where it fits
- Robotics software research
- Existing developer hardware
Specifications
Manufacturer-reported. Values apply to the configuration described here.
- Configuration
- Original CyberDog; earlier generation developer platform
- Locomotion
- Legged
- Dimensions / pose
- Not published
- Weight (kg)
- Not published
- Weight conditions
- Not published
- Walking payload (kg)
- Not published
- Payload conditions
- Not published
- Speed (m/s)
- Not published
- Speed conditions
- Not published
- Active runtime
- Not published
- Battery / charging
- Not published
- Ingress protection
- Not published
- Operating temperature
- Not published
- Terrain capability
- Not published
- Actuators / degrees of freedom
- Not published
- Perception / sensors
- Perception and navigation software modules; delivered hardware revision must be checked
- Connectivity / interfaces
- Not published
- Developer access
- Official ROS 2 Galactic packages; original platform uses an adapted Ubuntu 18.04 stack
Limitations & integration
Published capabilities depend on configuration and operating conditions. Confirm the supplied sensors, software permissions, accessories, service coverage and application requirements before purchase.