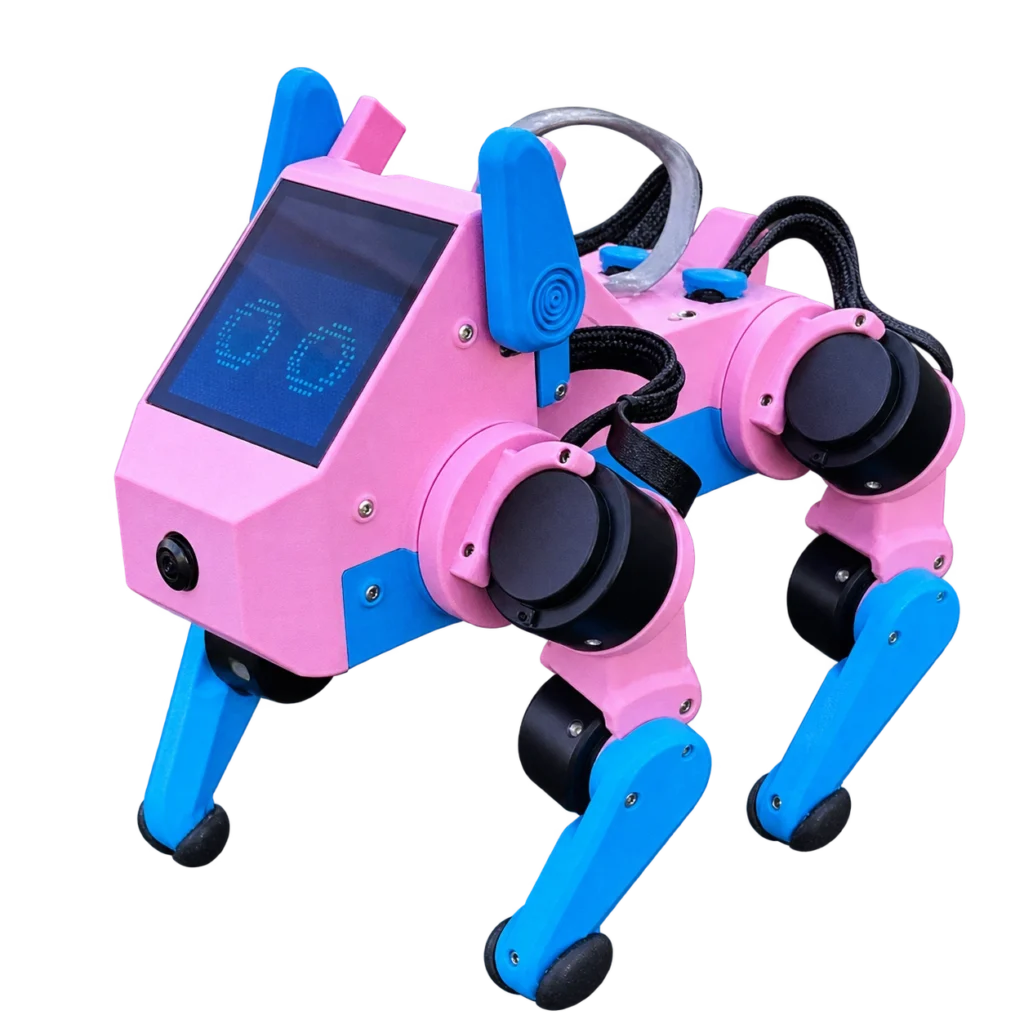
Overview
Pupper v3 is built from public hardware and software documentation. Its learning material connects mechanics, control, perception and AI experiments. The project’s approximate build budget is not an assembled robot purchase price, so procurement pricing remains contact-based rather than showing that budget as a retail offer.
Capabilities & applications
- Open-source hardware and software
- Expressive interaction
- Simulation-based learning
Where it fits
- Robotics courses
- AI and control experiments
Specifications
Manufacturer-reported. Values apply to the configuration described here.
- Configuration
- Pupper v3 open-source build
- Locomotion
- Legged
- Dimensions / pose
- 25 × 22 × 20 cm, crouched
- Weight (kg)
- 3
- Weight conditions
- Documented reference build weight
- Walking payload (kg)
- Not published
- Payload conditions
- Not published
- Speed (m/s)
- Not published
- Speed conditions
- Not published
- Active runtime
- Not published
- Battery / charging
- Not published
- Ingress protection
- Not published
- Operating temperature
- Not published
- Terrain capability
- Not published
- Actuators / degrees of freedom
- 12 leg DOF; ear servos additional
- Perception / sensors
- BNO086 IMU, IMX296 fisheye camera, microphone and actuator feedback
- Connectivity / interfaces
- Not published
- Developer access
- Open-source design and code; Raspberry Pi 5, 8 GB; optional AI accelerator
Limitations & integration
Published capabilities depend on configuration and operating conditions. Confirm the supplied sensors, software permissions, accessories, service coverage and application requirements before purchase.