Overview
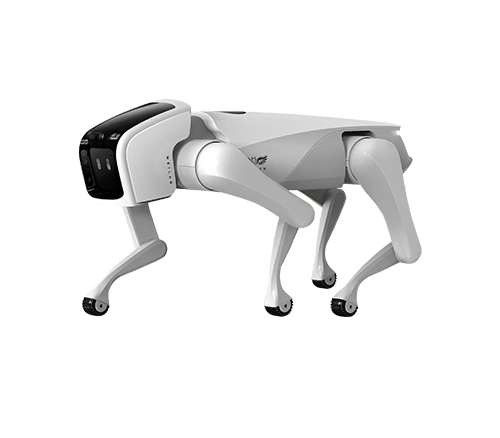
The C500 uses a Linux and ROS development environment with an extensible sensor ecosystem. C501 adds hardware and autonomous-navigation features that are not included in C500. Active walking runtime is shown instead of the much longer standby figure.
Capabilities & applications
- Developer expansion
- Dynamic balance
- Multiple gait modes
Where it fits
- AI application prototypes
- Robotics development
Specifications
Manufacturer-reported. Values apply to the configuration described here.
- Configuration
- Fifth-generation C500 standard developer version; not C501
- Locomotion
- Legged
- Dimensions / pose
- 76 × 40 × 45 cm, standing
- Weight (kg)
- 24
- Weight conditions
- Manufacturer listed weight; battery inclusion not explicitly stated
- Walking payload (kg)
- Not published
- Payload conditions
- Not published
- Speed (m/s)
- 1.5
- Speed conditions
- Up to 1.5 m/s normal listed speed; 3 m/s maximum safe speed is separate
- Active runtime
- Up to 3.3 hours continuous walking; 5.7 h average mixed use and 18 h standby are separate
- Battery / charging
- 23 Ah lithium battery
- Ingress protection
- Not published
- Operating temperature
- 0 to 35°C
- Terrain capability
- 20° maximum gradeability
- Actuators / degrees of freedom
- Not published
- Perception / sensors
- Fisheye vision, microphone array; depth camera not included in C500 column
- Connectivity / interfaces
- HDMI, USB, Wi-Fi and Bluetooth control
- Developer access
- Linux + ROS; Raspberry Pi, Arduino and M5Stack expansion ecosystem
Limitations & integration
Published capabilities depend on configuration and operating conditions. Confirm the supplied sensors, software permissions, accessories, service coverage and application requirements before purchase.