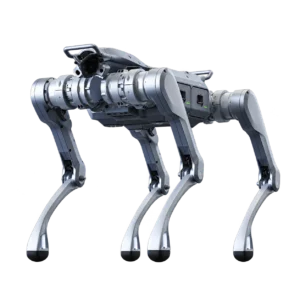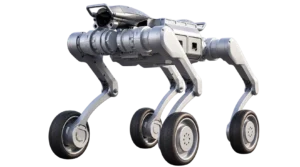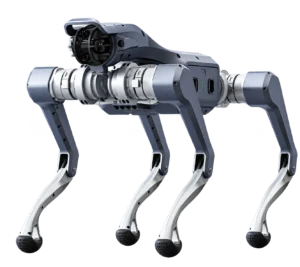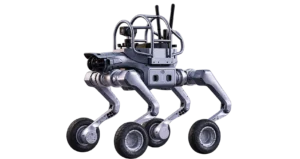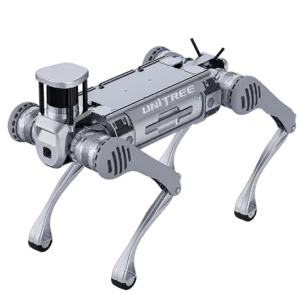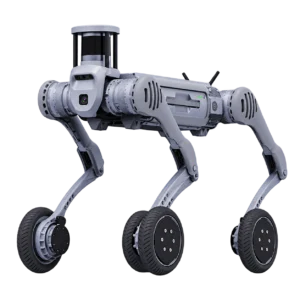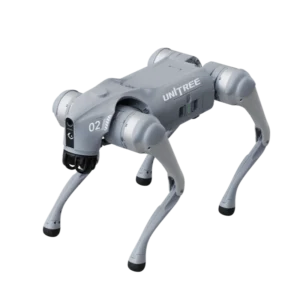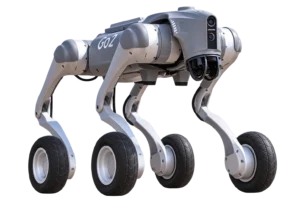
Overview
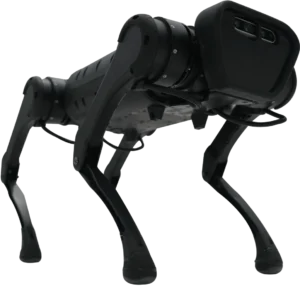
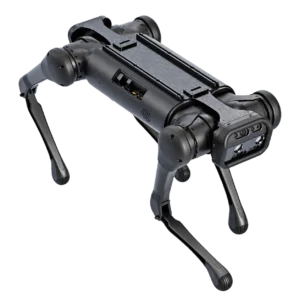
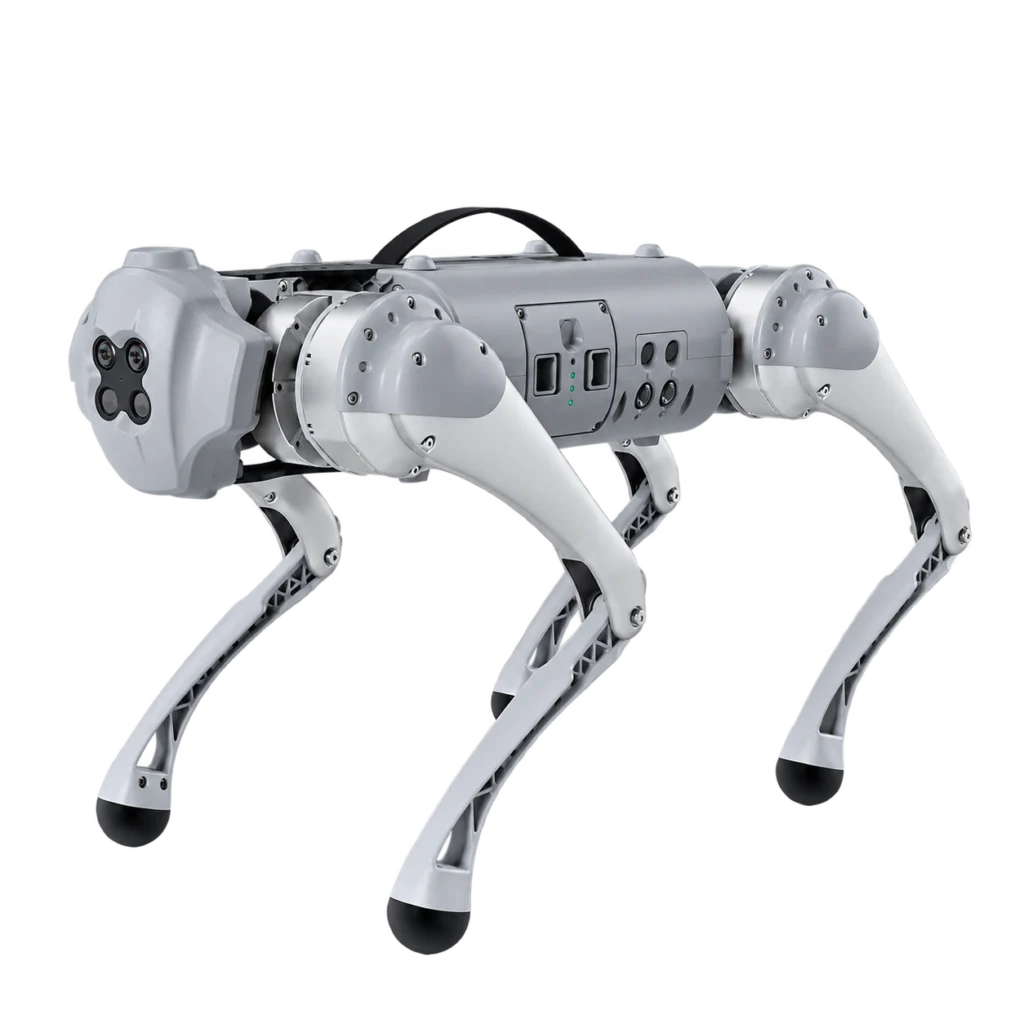
This earlier model remains useful as a reference for the evolution of compact quadrupeds. AIR, PRO and EDU have different perception and development features. The manufacturer storefront lists AIR and PRO as unavailable, so the displayed amount is a limited reference rather than a stock promise.
Capabilities & applications
- Remote-controlled locomotion
- Side-follow system
Where it fits
- Existing laboratory platforms
- Quadruped education
Specifications
Manufacturer-reported. Values apply to the configuration described here.
- Configuration
- Go1 AIR; earlier generation
- Locomotion
- Legged
- Dimensions / pose
- Not published
- Weight (kg)
- 12
- Weight conditions
- Manufacturer headline approximate weight
- Walking payload (kg)
- 4
- Payload conditions
- AIR normal load; 10 kg limit is not the normal payload
- Speed (m/s)
- 2.5
- Speed conditions
- AIR listed range; higher family demonstrations do not apply
- Active runtime
- Not published
- Battery / charging
- Not published
- Ingress protection
- Not published
- Operating temperature
- Not published
- Terrain capability
- Not published
- Actuators / degrees of freedom
- 12 joint motors
- Perception / sensors
- One binocular depth sensing pair in AIR; higher configurations differ
- Connectivity / interfaces
- Not published
- Developer access
- Scientific and Python interfaces listed for EDU, not AIR
Limitations & integration
Published capabilities depend on configuration and operating conditions. Confirm the supplied sensors, software permissions, accessories, service coverage and application requirements before purchase.