Overview
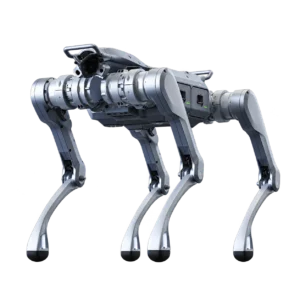
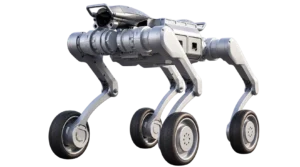
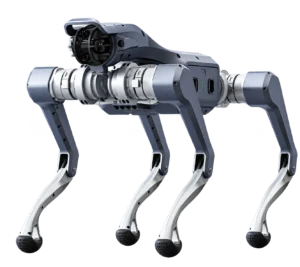
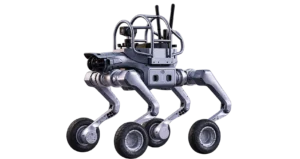
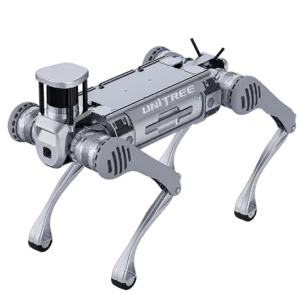
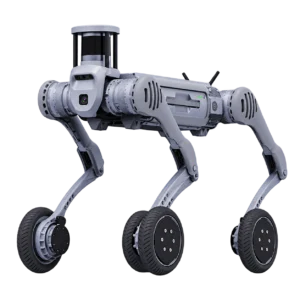
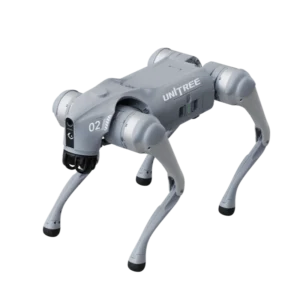
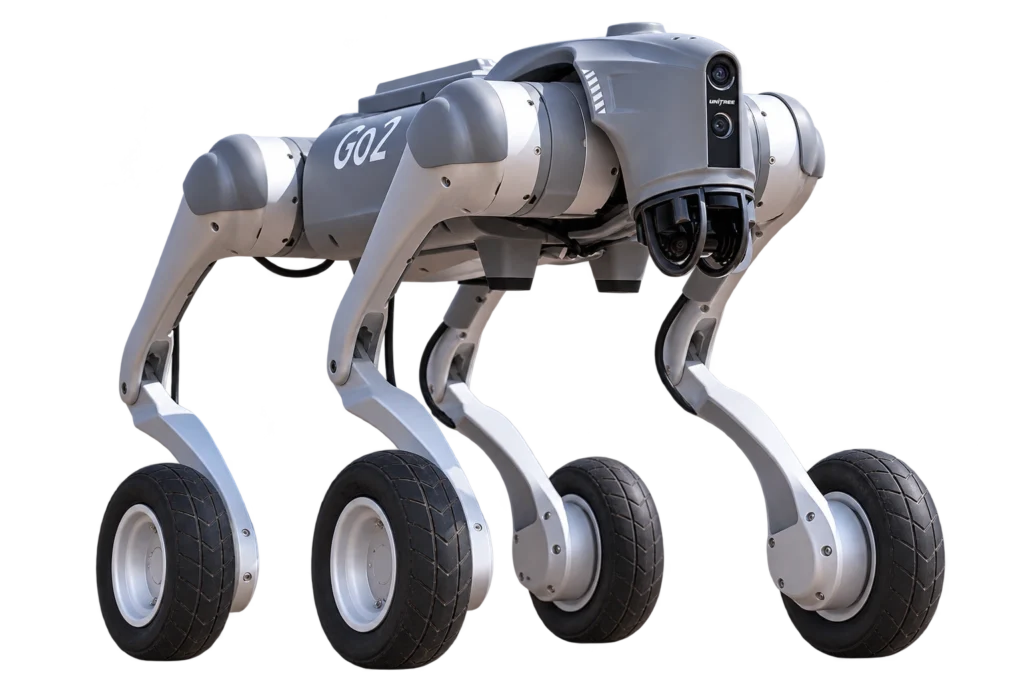
The wheel-legged design changes how this platform moves over smooth ground and obstacles. Its higher stance, additional motors and long-endurance battery make its specifications distinct from legged Go2. Navigation and compute accessories should be matched to the intended development project.
Capabilities & applications
- Wheel and leg mobility
- App control
- Developer expansion
Where it fits
- Hybrid locomotion research
- Mobile sensing prototypes
Specifications
Manufacturer-reported. Values apply to the configuration described here.
- Configuration
- Go2-W; configuration as described below
- Locomotion
- Wheel-legged
- Dimensions / pose
- 70 × 43 × 50 cm, standing
- Weight (kg)
- 18
- Weight conditions
- Approximate; battery included
- Walking payload (kg)
- 8
- Payload conditions
- Normal approximate payload; peak 12 kg listed separately
- Speed (m/s)
- 2.5
- Speed conditions
- Manufacturer listed 0–2.5 m/s range
- Active runtime
- 1.5–3 hours, long-endurance battery
- Battery / charging
- 15,000 mAh; 33.6 V / 9 A charger
- Ingress protection
- Not published
- Operating temperature
- Not published
- Terrain capability
- 35° slope; single obstacle claim below 70 cm
- Actuators / degrees of freedom
- 16 motors including wheel drives
- Perception / sensors
- Wide-angle LiDAR; HD camera
- Connectivity / interfaces
- Not published
- Developer access
- Secondary development supported; optional Orin NX compute
Limitations & integration
Published capabilities depend on configuration and operating conditions. Confirm the supplied sensors, software permissions, accessories, service coverage and application requirements before purchase.